
Introduction — a lab moment and a question
One afternoon I watched a junior researcher fumble with a clamp, sighing; the whole setup felt like slow-motion surgery, lah. The second sentence here: we were testing an automated stereotaxic Instrument to speed things up and reduce error, and I could see the change almost immediately. Labs report roughly 20–30% less setup time and fewer misaligned targets after automation (numbers vary, but the trend is clear). So — why do some teams still shy away from automation when the practical gains are visible? I want to share what I’ve learned, in plain terms, and give you usable ideas you can try tomorrow.
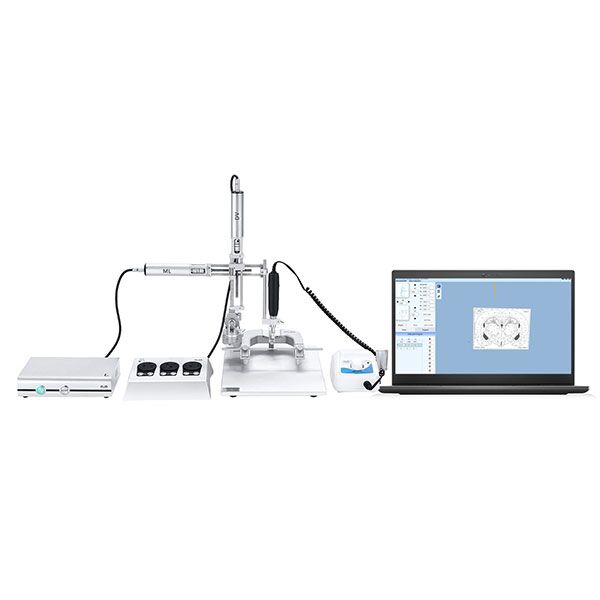
Deeper problems: why traditional methods stumble
Why do these tools fail?
Let me be blunt: old-school rigs and manual workflows break down in predictable ways. When we work with stereotaxic mice, the game is about repeatable targets and tight tolerances. Traditional setups lean heavily on human alignment, which makes stereotaxic coordinates drift over time. I’ve seen teams spend hours re-calibrating a micro-manipulator because a clamp slipped — messy, right? The core failure modes are simple: human error, poor 3D positioning feedback, and a lack of real-time monitoring.
From a technical angle, legacy rigs often rely on coarse stepper motors and manual readouts. That means you end up chasing hundred-micron errors with subjective judgment calls. Add to that low-resolution imaging and limited data logging, and you’ve got a process that can’t scale. Look, it’s simpler than you think — automate the repetitive bits, keep humans where nuanced decisions matter. The result: fewer failed runs, cleaner datasets, and less frustration at 2 a.m.
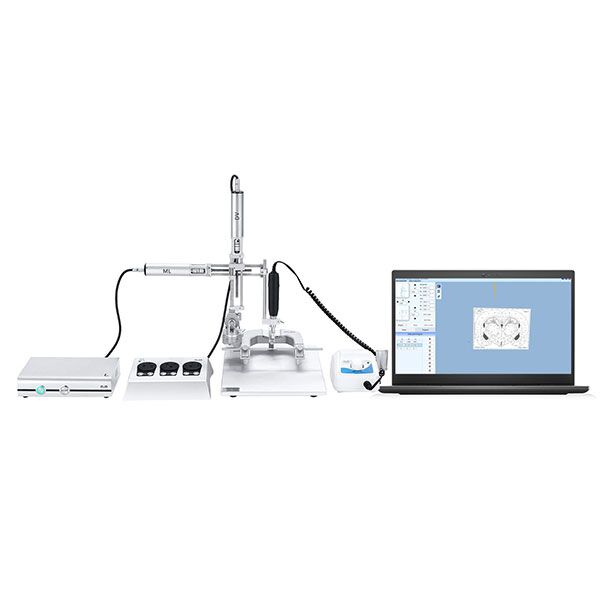
Looking ahead — new principles that actually help
What’s next?
I want to talk about practical principles, not hype. Modern systems for stereotaxic mice blend precise 3D positioning, closed-loop feedback, and smart automation algorithms. In plain terms: use high-resolution imaging to confirm target, let the control system correct in real time, and log everything so you can review and improve. That trio — imaging, feedback, and data — is the backbone of better outcomes. We’ve seen micro-manipulator designs move from “set-and-forget” to continuous correction, and that matters when you measure success by hit rate and reproducibility.
There’s also a human side. I believe systems work best when they reduce cognitive load for operators. So interfaces should be clear, prompts minimal, and error states obvious. I’ve watched teams adopt automation and — funny how that works, right? — suddenly trust grows. They run more experiments, and the data quality goes up. For labs evaluating options, consider three quick metrics: precision consistency (how tight are repeated coordinates?), throughput improvement (time saved per procedure), and auditability (does the system log runs in enough detail to troubleshoot?). These are not fancy; they are useful. If you want a practical starting point, check system calibration routines, imaging resolution, and whether the control software supports automated correction loops. For further reference and equipment, see BPLabLine.
